Mechanical Engineering · Product Design · Robotics/Mechatronics

Developing electromechanical and robotic systems for prosthetics, rehabilitation, and wearable technologies.

Mechanical engineer with hands-on experience in mechanical design, product development, mechatronic integration, wearable robotics, prosthetics, pneumatic systems, FEA-based validation, biomechanics, and experimental testing.
Souvik Poddar
Mechanical DesignCAD, mechanisms, fixtures, assemblies, wearable hardware, and design validation
Product DevelopmentPrototype iteration, benchtop testing, validation, and design improvement
Robotics/MechatronicsActuators, motors, electronics hardware, sensor integration, controller development, closed-loop control, PID control, motor control, pressure/flow regulation, DAQ, and trajectory tracking

News

Recent updates

Research, career, and publication milestones.

October 2026

IEEE Access paper accepted

A Feasibility Study Comparing Body-Powered and Myoelectric Prostheses Using Plug-and-Play Module was accepted for publication in IEEE Access.

September 2026

Joined KAIST Exo Lab as an InnoCore Postdoctoral Scholar

Received InnoCore funding and joined Exo Lab at KAIST, working with Prof. Kong on an NVIDIA-supported Human-Machine Foundation Model project for motion inference from sparse wearable sensors.

September 2026

Gait-training robot controller paper accepted

Enhanced Feedforward Force Controller for Cyclic Disturbance Compensation in a Gait-Training Robot was accepted in IEEE Transactions on Medical Robotics and Bionics.

June 1, 2026

Graduated with a PhD in Mechanical Engineering

Graduated from the University at Buffalo with a PhD in Mechanical Engineering.

About

Background

Experience across mechanical design, mechatronics, controller development, soft robotics, wearable hardware, and human-subject biomechanics for systems that support movement, rehabilitation, and prosthetic function.

I work across the full development cycle: problem definition, CAD design, prototyping, actuation and sensing, controller development, finite element analysis, experimental setup, data collection, and performance evaluation.

This portfolio highlights projects in transradial prosthesis emulation, cerebral palsy gait training, portable pneumatic systems, inflatable actuator composites, soft insole sensors, fabric-based soft ankle modules, and automated security gate design, with controller development, sensor-feedback workflows, and closed-loop robotics/mechatronics experience included where applicable.

Academic background

Education

Formal training in mechanical engineering, production engineering, robotics, biomechanics, and wearable robotic systems.
University at Buffalo logo

University at Buffalo, USA

PhD, Mechanical Engineering

June 1, 2026
Arizona State University logo

Arizona State University, USA

MS, Mechanical Engineering

May 2020

National Institute of Technology Agartala logo

National Institute of Technology Agartala, India

BTech, Production Engineering

May 2018

Professional background

Experience

Research, engineering, and product-development experience across wearable robotics, rehabilitation, prosthetics, and automation.
KAIST logo

Korea Advanced Institute of Science and Technology (KAIST), South Korea

InnoCore Postdoctoral Scholar

September 2026 – Present

Received InnoCore funding and joined Exo Lab under Prof. Kong. Developing an NVIDIA-supported Human-Machine Foundation Model for motion inference from sparse wearable sensors, synthetic IMU methods, and wearable rehabilitation robotics.

University at Buffalo logo

University at Buffalo, USA

Research Assistant

August 2020 – June 2026

Designed, integrated, and validated robotic prosthesis emulators and gait-rehabilitation systems, including CAD, mechatronic hardware, closed-loop control, sensing, test fixtures, and human-subject studies.
University of Michigan logo

University of Michigan, USA

Visiting Scholar

January 2025 – January 2026

Led a prosthesis-emulator user study, developed experimental fixtures and protocols, and analyzed how prosthesis weight affects task performance, upper-limb kinematics, workload, and fatigue.

Arizona State University logo

Arizona State University, USA

Research Assistant

August 2018 – May 2020

Developed and tested soft wearable-robotics technologies, including inflatable actuator composites, portable pneumatic control systems, soft ankle modules, and inflatable insole sensors using FEA and benchtop validation.
Indian Institute of Technology Patna logo

Indian Institute of Technology Patna, India

Project Intern

May 2017 – July 2017

Designed and prototyped an automated security gate using CAD, rack-and-pinion transmission, motor sizing, control logic, torque calculations, and fabrication-oriented design.
Hindustan Unilever logo

Hindustan Unilever, India

Project Intern

May 2016 – June 2016

Supported industrial project work involving mechanical systems, manufacturing processes, and practical product-development workflows.

Projects

Selected work

These projects show hands-on hardware development, mechanical design, FEA, robotics/mechatronics, and wearable robotics experience.
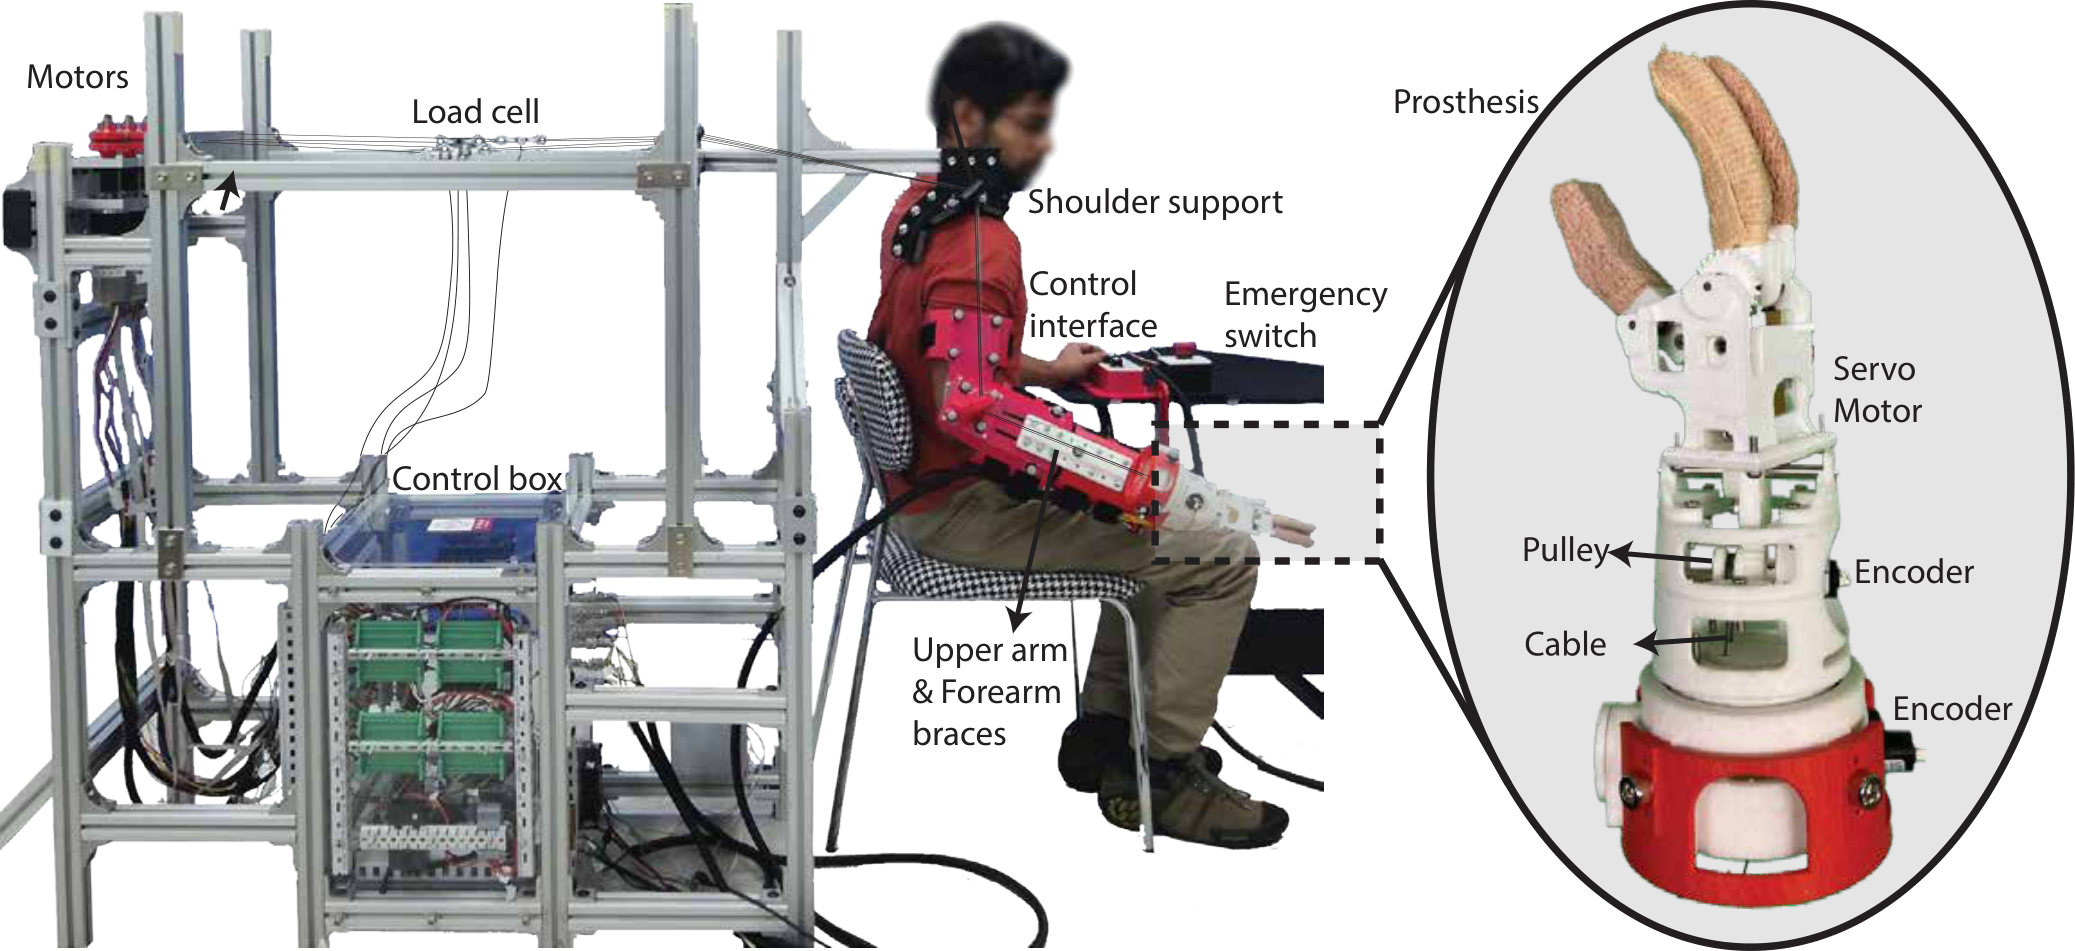
Electromechanical designReal-time closed-loop controlMotor controlSensor integrationTrajectory trackingDesign validation
I-PEDLE robotic prosthesis emulator

Robotic Prosthesis Emulator for User-Driven Design of Multi-DOF Transradial Prostheses

Affiliation: University at Buffalo, USA

Designed and validated a compact cable-driven electromechanical prosthesis emulator with motors, sensors, PID-based closed-loop control, test fixtures, and user-centered design evaluation.

Read project →
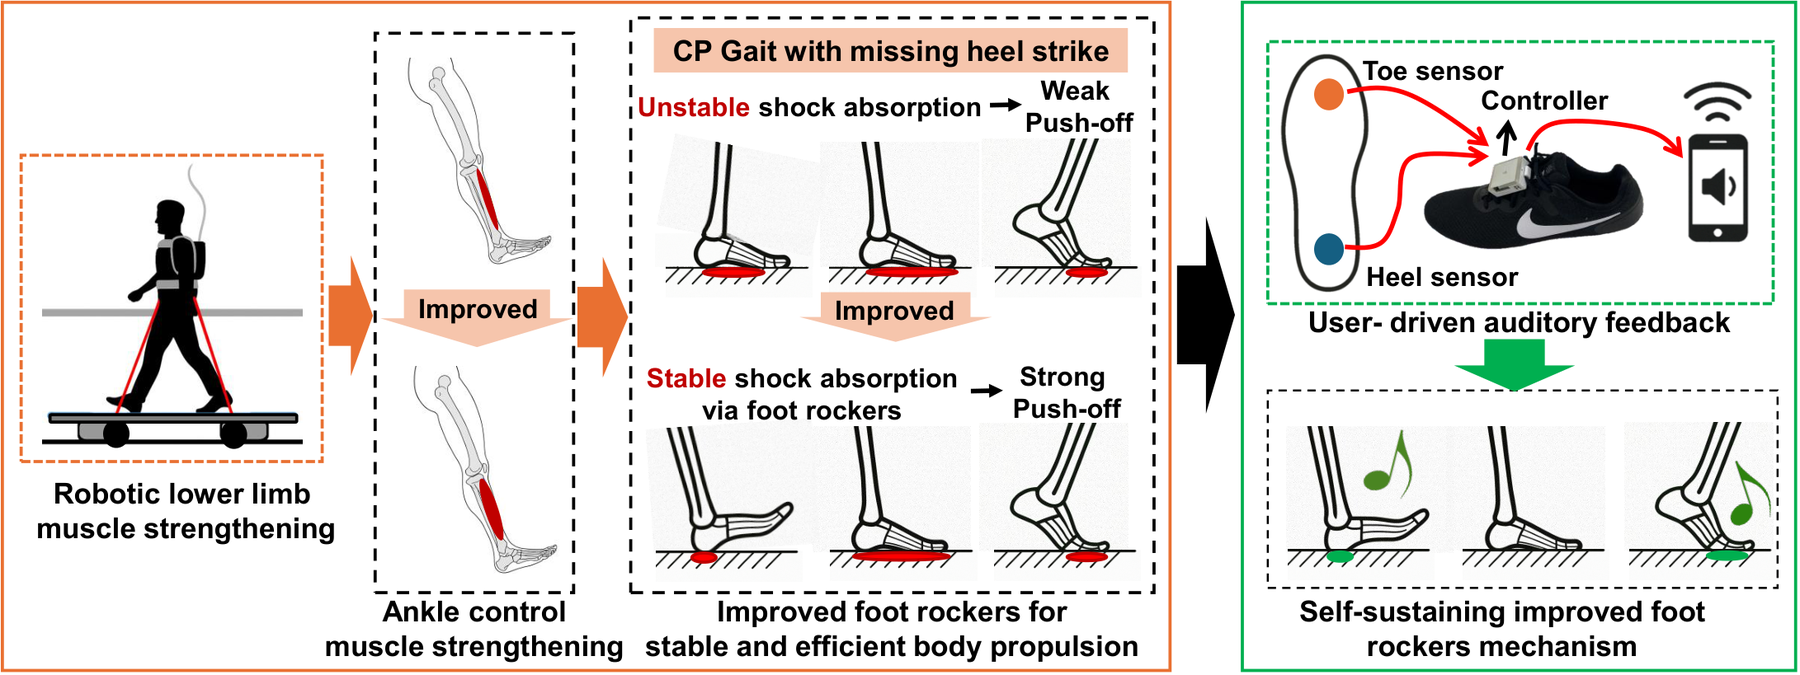
Robotic testingClosed-loop controlDAQMotion captureEMGHuman-subject testing
Cerebral palsy gait training intervention

Robot-Resisted Gait Training With Auditory Biofeedback in Adults With Cerebral Palsy

Affiliation: University at Buffalo, USA

Implemented a robotic gait-training workflow involving controlled resistance, closed-loop robotic testing, DAQ, motion capture, EMG, troubleshooting, and experimental validation with participants.

Read project →
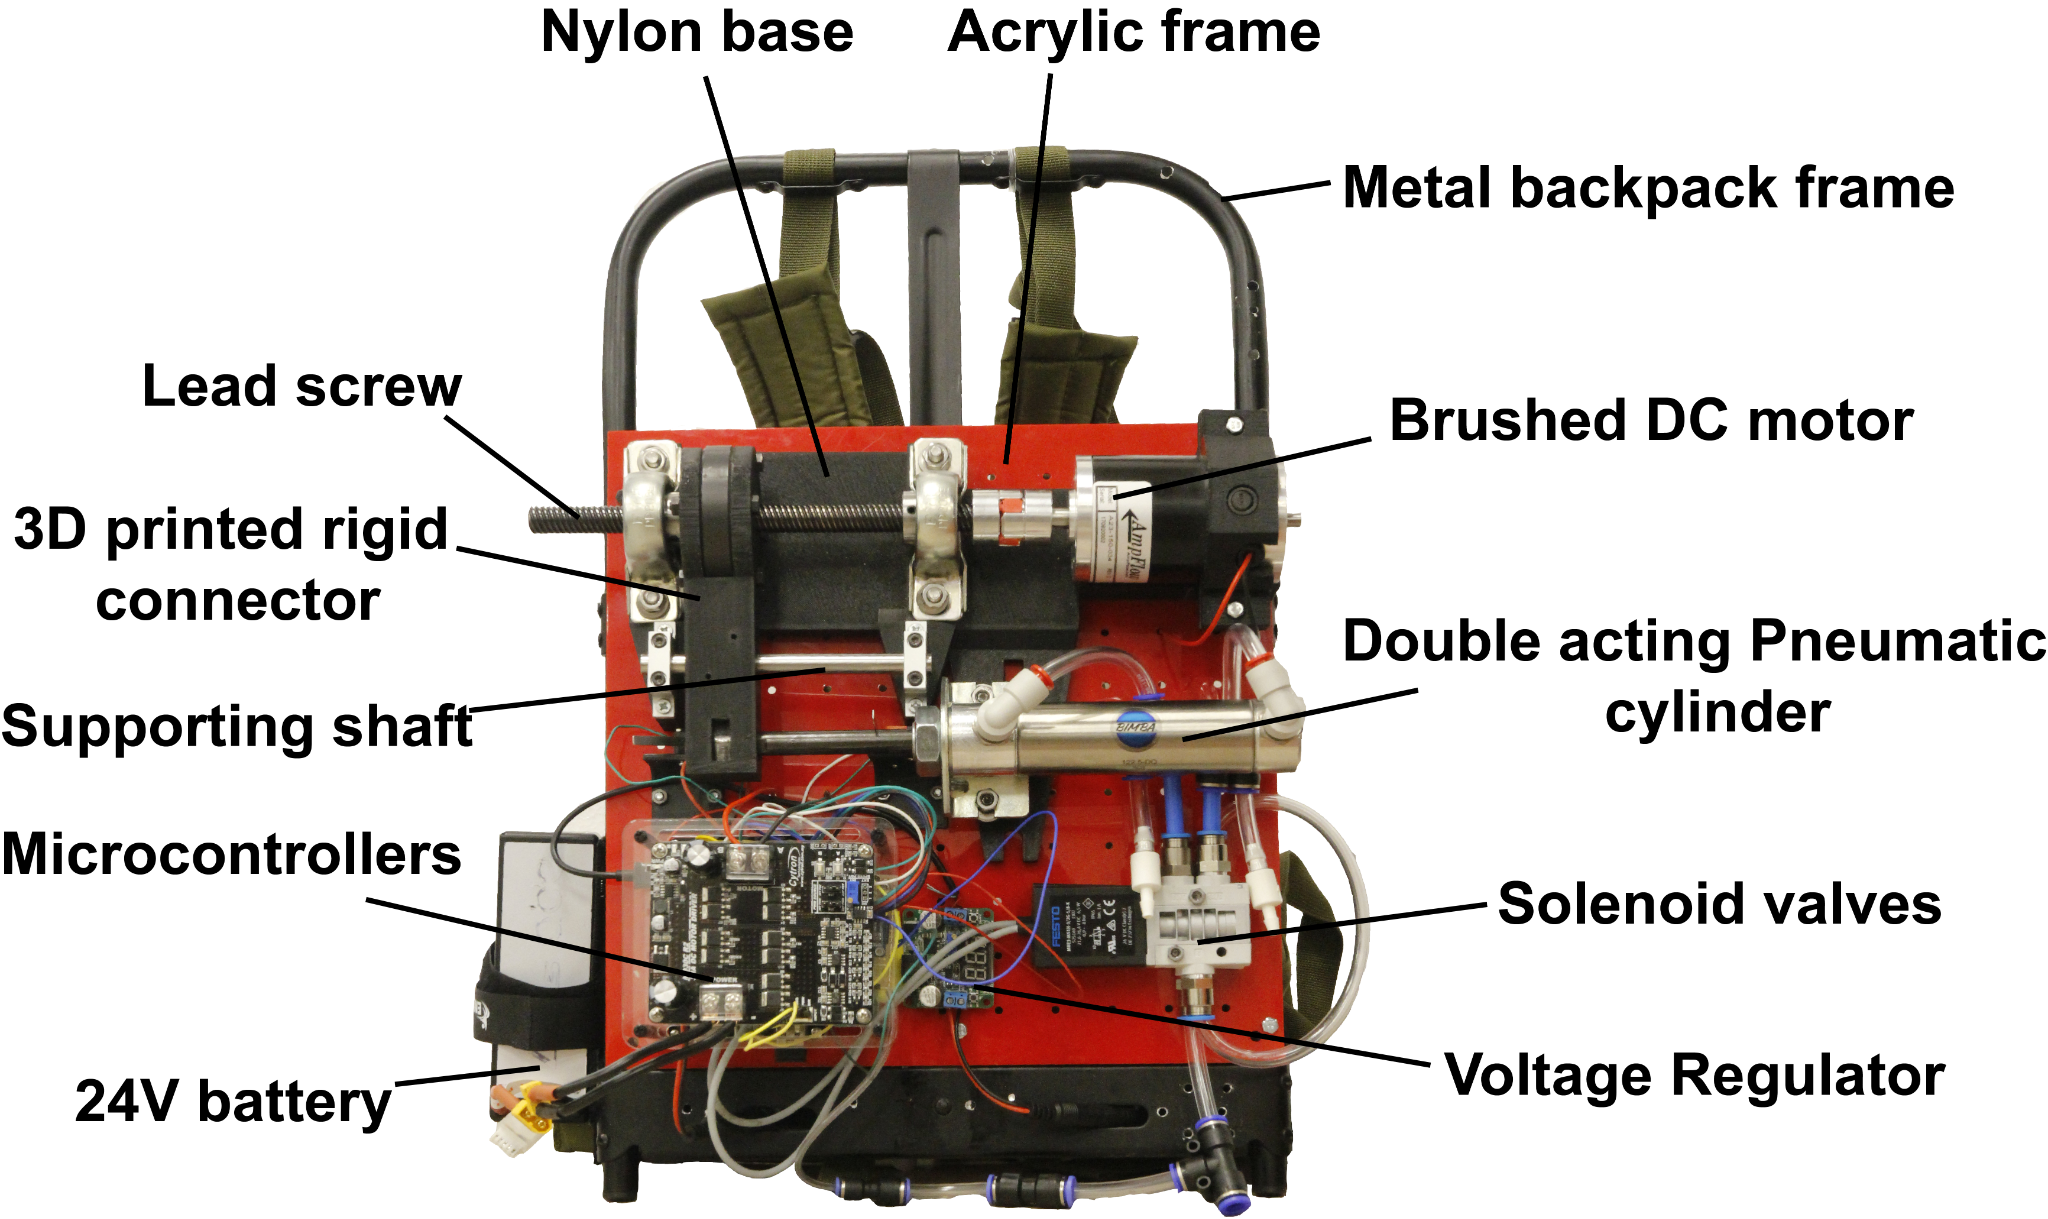
Pneumatic hardwareElectronics hardwareEmbedded controlPressure/flow controlPressure sensingValve integrationSystem integration
Portable pneumatic source hardware

Portable Pneumatic Source for Wearable Soft Robotics

Affiliation: Arizona State University, USA

Built and tested a portable pneumatic hardware platform integrating motorized actuation, valves, pressure/flow sensing, electronics hardware, and embedded control for pneumatic actuation.

Read project →
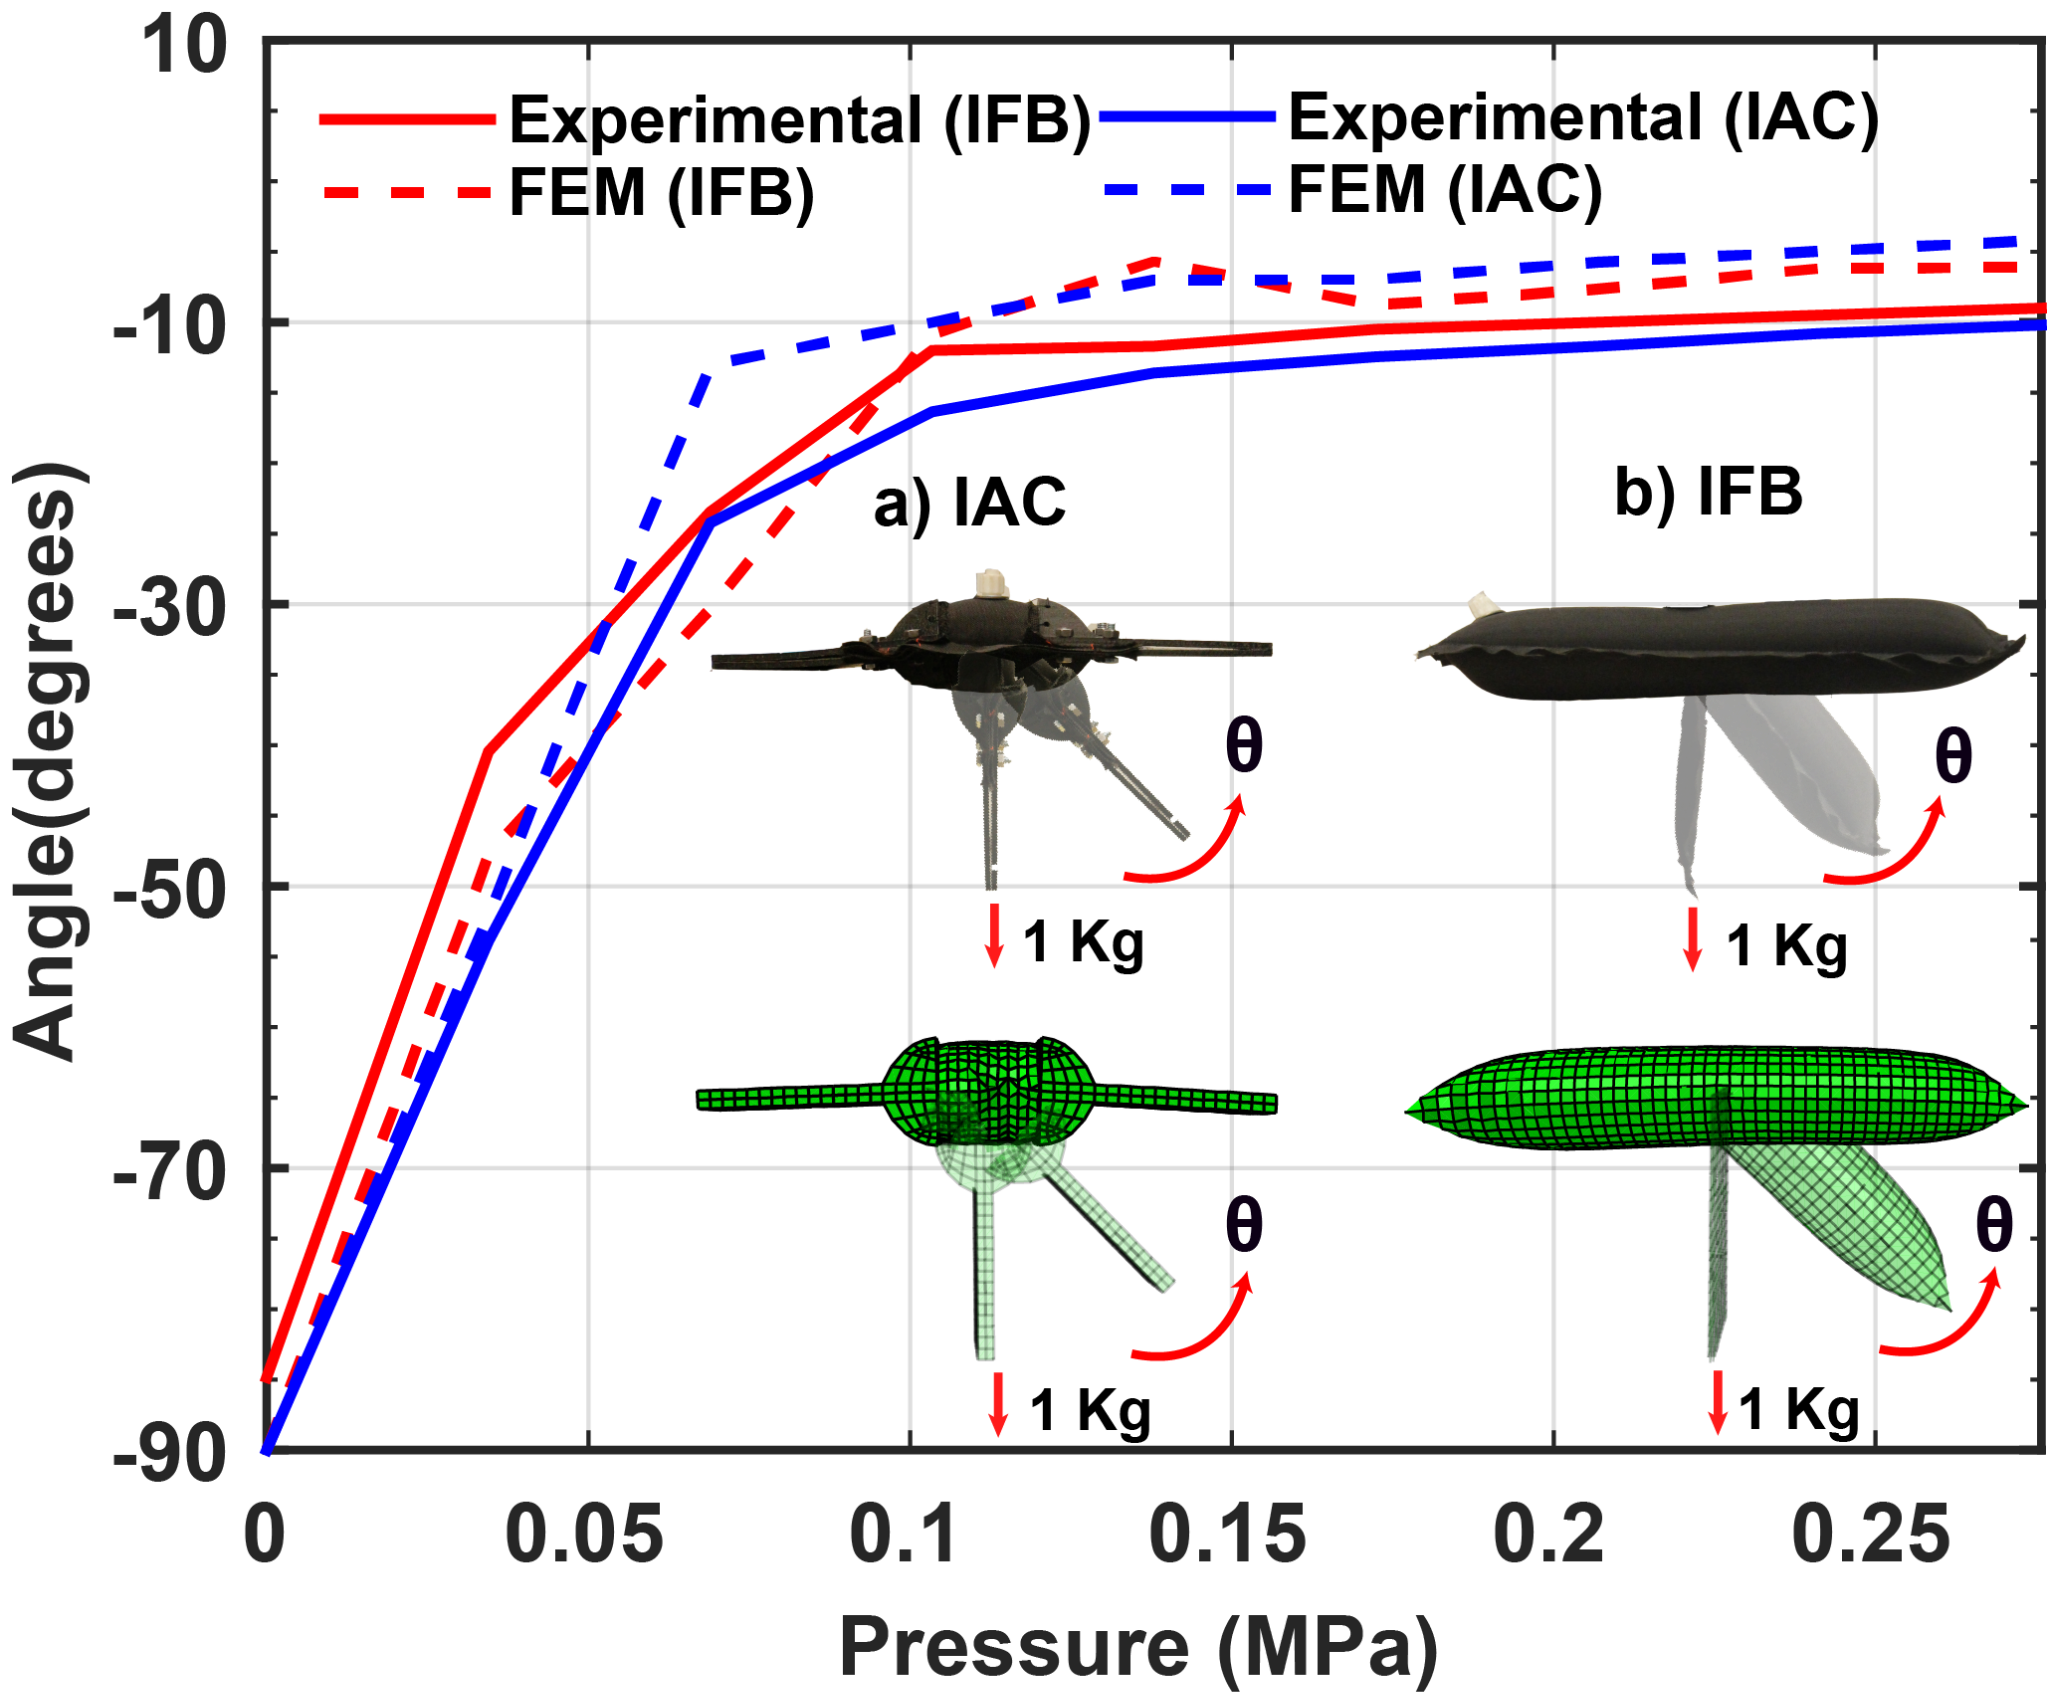
FEA validationDesign optimizationAbaqusSimulation correlationPython automationPrototype testing
Inflatable actuator composite FEA

FEA and Design Optimization of Inflatable Actuator Composites

Affiliation: Arizona State University, USA

Performed FEA-driven design optimization and simulation-to-test validation of inflatable actuator composites using Abaqus, Python automation, and benchtop experiments.

Read project →
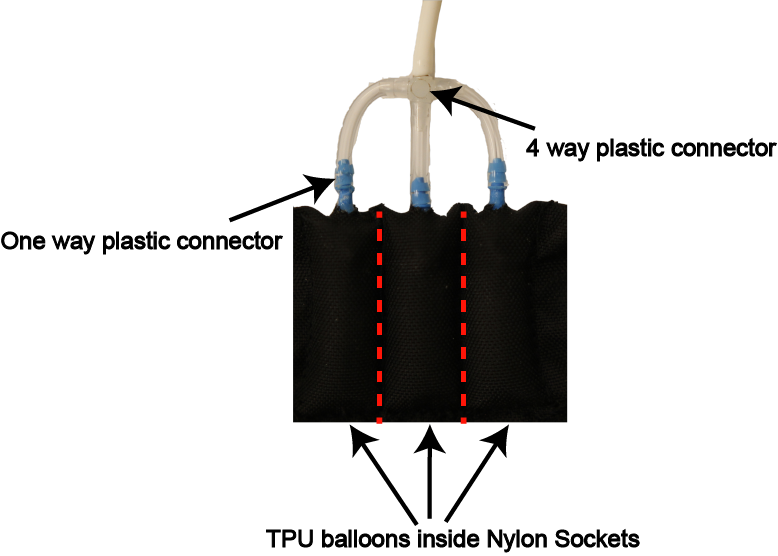
Sensor developmentWearable hardwareSoft sensorsLoad testingSignal characterizationValidation
Inflatable insole sensor design

Fabric-Based Inflatable Insole Sensors for Gait Detection

Affiliation: Arizona State University, USA

Developed wearable soft sensors through iterative fabrication, load testing, signal characterization, and gait-event validation for insole-based sensing.

Read project →
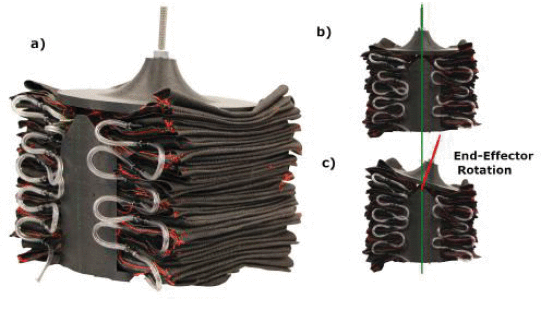
Wearable deviceActuator integrationSoft roboticsStiffness characterizationPrototype validationPneumatic actuation
Fabric-based soft ankle module

Fabric-Based Soft Ankle Module to Mimic Human Ankle Stiffness

Affiliation: Arizona State University, USA

Supported fabrication, actuator integration, torque-pressure characterization, stiffness testing, and validation of a wearable soft ankle module designed to reproduce ankle-like stiffness behavior.

Read project →
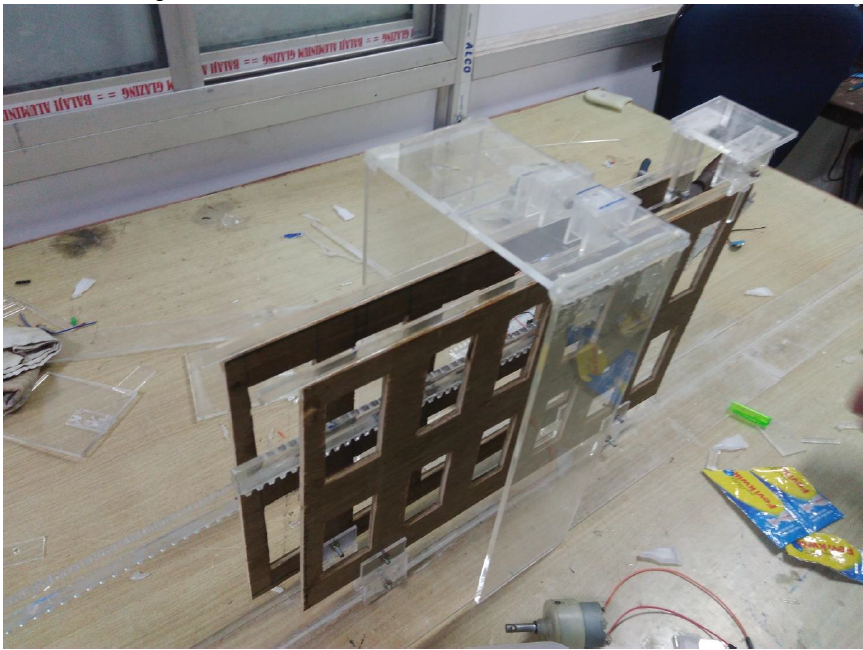
Industrial automationMotor sizingMotor controlDFMRack-and-pinion driveTorque calculationPrototype fabrication
Automated security gate CAD model

Automated Security Gate Design and Prototype

Affiliation: Indian Institute of Technology Patna, India

Designed an industrial-style automated sliding gate using CAD, rack-and-pinion transmission, motor sizing, control logic, torque calculations, DFM thinking, and prototype fabrication.

Read project →
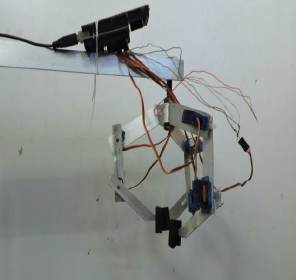
Robotic end-effectorIn-house fabricationServo actuation/controlMechanism designHardware assemblyLoad testing
Three-finger gripper working prototype

Three-Finger Gripper Actuated by Micro Servos

Affiliation: National Institute of Technology Agartala, India

Designed, in-house fabricated, assembled, and evaluated a servo-actuated robotic end-effector using custom mechanical hardware, servo control, and load-response testing.

Read project →

Documents

Resume and CV

Download a concise resume or a detailed CV with publications, engineering experience, teaching, patents, awards, and presentations.

ResumeConcise overview

Resume

A concise resume focused on mechanical engineering, electromechanical systems, product development, mechatronic integration, prototyping, testing, and FEA-based design validation.

Download Resume
CVFull academic record

CV

A detailed CV including education, peer-reviewed journal and conference papers, engineering experience, teaching experience, patents, awards, fellowships, posters, and talks.

Download CV

Publications

Publications and technical contributions

Click each heading to expand journal papers, conference papers, patents, thesis/dissertation work, talks, presentations, and posters. Google Scholar is listed separately below.

Peer-reviewed Journal Papers 7

Understanding Weight and Performance Trade-Offs in Transradial Prostheses Using a Robotic Emulator

Manuscript under preparation, 2026

Poddar et al.

A Feasibility Study Comparing Body-Powered and Myoelectric Prostheses Using Plug-and-Play Module

IEEE Access, accepted for publication, 2026

Rishi Adusumilli, Souvik Poddar, Mohamed Sulaiman, and Jiyeon Kang.

Enhanced Feedforward Force Controller for Cyclic Disturbance Compensation in a Gait-Training Robot

IEEE Transactions on Medical Robotics and Bionics, 2026

Jin-Woo Lee*, Sahil Kapahi*, Souvik Poddar, and Jiyeon Kang.

A Robotic Emulator for User-Driven Design of Multi-DOF Transradial Prostheses

IEEE Robotics and Automation Letters, 2026

Souvik Poddar, Eleonora M. Botta, Deanna H. Gates, and Jiyeon Kang.

Improving Foot Rocker via Robot-Resisted Gait Training With Self-Awareness Biofeedback in Adults With Cerebral Palsy

IEEE Transactions on Neural Systems and Rehabilitation Engineering, 2025

Souvik Poddar, Jaehyung Park, Eleonora M. Botta, Lora Cavuoto, Jeanne Langan, and Jiyeon Kang.

Gait Sensing and Haptic Feedback Using an Inflatable Soft Haptic Sensor

ASME Letters in Dynamic Systems and Control, 2024

E. Quinones Yumbla, J. Rokalaboina, A. Kanechika, Souvik Poddar, T. M. Nibi, and Wenlong Zhang.

Towards Untethered Soft Pneumatic Exosuits Using Low-Volume Inflatable Actuator Composites and a Portable Pneumatic Source

IEEE Robotics and Automation Letters, 2020

Saivimal Sridar, Souvik Poddar, Yida Tong, Panagiotis Polygerinos, and Wenlong Zhang.

Peer-reviewed Conference Papers 3

A Lightweight Transradial Prosthetic Emulator for Optimizing Prosthetic Wrist Design

IEEE RAS/EMBS International Conference for Biomedical Robotics and Biomechatronics, 2022

Souvik Poddar and Jiyeon Kang.

A Cable-Actuated Prosthetic Emulator for Transradial Amputees

Annual International Conference of the IEEE Engineering in Medicine & Biology Society, 2021

Souvik Poddar, David Cummiskey, and Jiyeon Kang.

Design, Development, and Control of a Fabric-Based Soft Ankle Module to Mimic Human Ankle Stiffness

IEEE International Conference on Rehabilitation Robotics, 2019

Sunny Amatya, Amir Salimi Lafmejani, Souvik Poddar, Saivimal Sridar, Thomas Sugar, and Panagiotis Polygerinos.

Patents 1

Low-Volume Inflatable Actuator Composites for Wearable Applications and Portable Pneumatic Source

U.S. Patent US 12,458,556 B2, issued 2025

Patent related to low-volume inflatable actuator composites and portable pneumatic source technology.

Thesis and Dissertation 2

Design, Development and Evaluation of a Robotic Emulator for User-Driven Design of Multi-DOF Transradial Prostheses

PhD Dissertation, University at Buffalo, USA, 2026

Souvik Poddar.

Design of a Portable Pneumatic Exosuit for Knee Extension Assistance with Gait Sensing using Fabric-Based Inflatable Insole Sensors

MS Thesis, Arizona State University, USA, 2020

Souvik Poddar.

Talks, Presentations & Posters 4

Fabrication and Experimental Investigation of a Three-Finger Robotic Gripper Actuated by Micro Servos

Oral Presentation, International Conference on Precision, Meso, Micro and Nano Engineering (COPEN 2019), IIT Indore, India

Souvik Poddar and Kishan Choudhuri.

Gait Sensing using Fabric-based Soft Inflatable Actuators and Force Haptic Feedback

Poster Presentation, MORE Spring 2020, Arizona State University, USA

Souvik Poddar.

Towards Portability of Pneumatic Wearable Devices using Low-Volume Inflatable Actuator Composites and a Portable Pneumatic Source

Poster Presentation, MORE Fall 2019, Arizona State University, USA

Souvik Poddar.

A Soft Inflatable Exosuit to Assist Knee Swing During Walking

Oral Presentation, ASU Southwest Robotics Symposium, Arizona State University, USA, 2018

Presented on behalf of RISE Lab, Wenlong Zhang.

Google Scholar

Citation record and publication updates

View Google Scholar

Awards & Funding

Awards, patent, and funding support

Selected recognitions and funding acknowledgments related to my engineering and robotics work.

NSF Disability and Rehabilitation Engineering (DARE) Program Support

PhD research was supported by the National Science Foundation DARE program under award CBET-2221979.

Master’s Opportunity for Research in Engineering (MORE) Award

Arizona State University, USA, August 2019 – May 2020.

U.S. Patent US 12,458,556 B2

Low-volume inflatable actuator composites for wearable applications and portable pneumatic source. Issued 2025.

Media Coverage

In the news

Korean media coverage of rehabilitation robotics, cerebral palsy gait training, and user-driven prosthesis design.

로봇신문Cerebral Palsy Gait Training

GIST-뉴욕주립대, 뇌성마비환자 보행 개선 로봇 재활기술 개발

Korean news coverage of the cerebral palsy gait-training project using robot-resisted treadmill training and self-awareness auditory biofeedback.

Read article
디지털타임스I-PEDLE

로봇, ‘맞춤형 의수 설계’ 맡는다…손목 동작 정밀 구현

Korean news coverage of the I-PEDLE robotic prosthesis experience system and its role in user-centered prosthesis design.

Read article

Training / Certifications

Training and certifications

Selected certificates from technical training programs in web development, CAD, automotive systems, embedded systems, and robotics. Use the compact link on each card to open the full certificate.

Training certificateSkills learned in training

Web Development Training

Six-week online winter training completed through Internshala.

Skills learned in training

  • HTML
  • Bootstrap
  • PHP
  • MySQL
  • Advanced PHP modules
View full certificate →
Training certificateSkills learned in training

Internshala Trainings Platinum Award

Certificate of appreciation recognizing participation as an Internshala Student Partner and Platinum Award recipient.

Skills learned in training

  • Student outreach
  • Communication
  • Program engagement
  • Training promotion
  • Professional networking
View full certificate →
Training certificateSkills learned in training

Automobile Systems and SAE Car Fabrication & Designing

Internship programme at AUTO-NEXT / Tata Motors Training Consultant.

Skills learned in training

  • Automobile basics
  • Advanced automotive systems
  • SAE car fabrication
  • Vehicle design exposure
  • Hands-on automotive training
View full certificate →
Training certificateSkills learned in training

Embedded Systems & Robotics

Training in Embedded Systems & Robotics at i3indya Technologies, Kolkata.

Skills learned in training

  • Embedded systems fundamentals
  • Robotics basics
  • Hardware integration
  • Electronics exposure
  • System-level thinking
View full certificate →
Training certificateSkills learned in training

Overview of SolidWorks

Course completed at MSME Tool Room Kolkata / Central Tool Room & Training Centre.

Skills learned in training

  • SolidWorks overview
  • CAD modeling fundamentals
  • Mechanical design workflow
  • Part modeling exposure
  • Design documentation
View full certificate →
Training certificateSkills learned in training

Basic Robotics + Advanced Robotics

Approved course through A-NARC, NIT Agartala Robotics Club.

Skills learned in training

  • Basic robotics
  • Advanced robotics
  • Robot mechanisms
  • Robotics concepts
  • Applied technical learning
View full certificate →
Training certificateSkills learned in training

CATIA V6

CATIA V6 course completed at MSME Tool Room Kolkata / Central Tool Room & Training Centre.

Skills learned in training

  • ENOVIA introduction
  • Part design
  • Generative shape design
  • Sheet metal design
  • Assembly design
  • Kinematics analysis
  • Drafting
  • Machining exposure
View full certificate →

Skills

Technical areas

Skills across mechanical design, robotics/mechatronics, electronics hardware integration, biomechanics, and experimental validation.

Design & Prototyping

CAD, 3D printing, mechanical design, test fixtures, soft robotic components, wearable hardware integration.

FEA & Modeling

ABAQUS, SolidWorks, soft-rigid actuator modeling, pressure-deflection simulation, experimental validation.

Robotics/Mechatronics & Electronics Hardware

Electromechanical hardware, microcontrollers, motor drivers, DAQ, encoders, pressure sensors, signal conditioning, controller development, closed-loop control, PID control, motor control, pressure/flow regulation, trajectory tracking, and system integration.

Biomechanics & Testing

Motion capture, EMG, gait analysis, human-subject protocols, statistical analysis, experimental evaluation.

Contact

Let’s connect

For collaborations, speaking opportunities, technical discussions, or professional inquiries, feel free to reach out.